About Me
I am a robotics researcher specializing in physically grounded robot learning for contact-rich dexterous manipulation. My work focuses on sim-to-real reinforcement learning, tactile and multimodal perception, and real-time robotic systems that remain reliable under real-world contact.
I received my Ph.D. in Computer Science from the University of Alabama, where I worked with Dr. Hongsheng He in the Autonomous Robotics Lab. During my Ph.D., I built DexMobile, a 40-DoF bimanual mobile manipulation platform integrating dual robotic arms, dexterous hands, tactile sensing, vision-based pose tracking, and real-time ROS 2 control. The system achieved 83% real-world grasp success across 500+ hardware trials and 88% sim-to-real transfer.
I also developed Physically Structured Policy Learning (PSPL), a framework that structures policy learning around contact physics to improve exploration, efficiency, and reliability in manipulation tasks. My research has been published in venues including ICRA, Humanoids, and ICSR, and my work has been supported by the NSF I-Corps program for technology commercialization.
Selected Publications
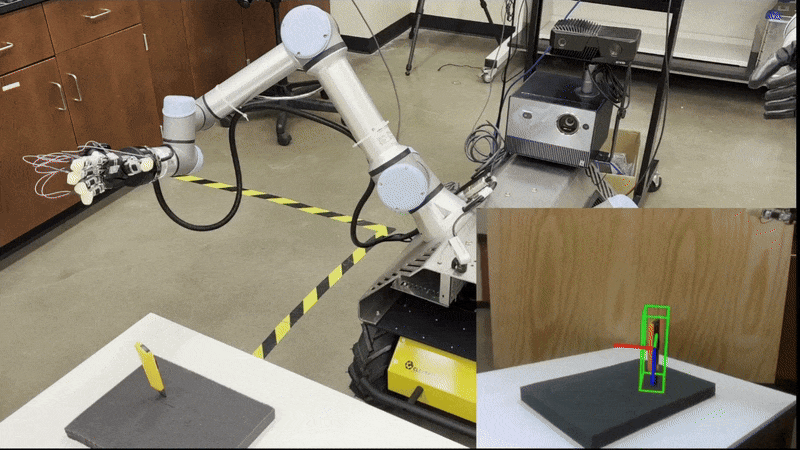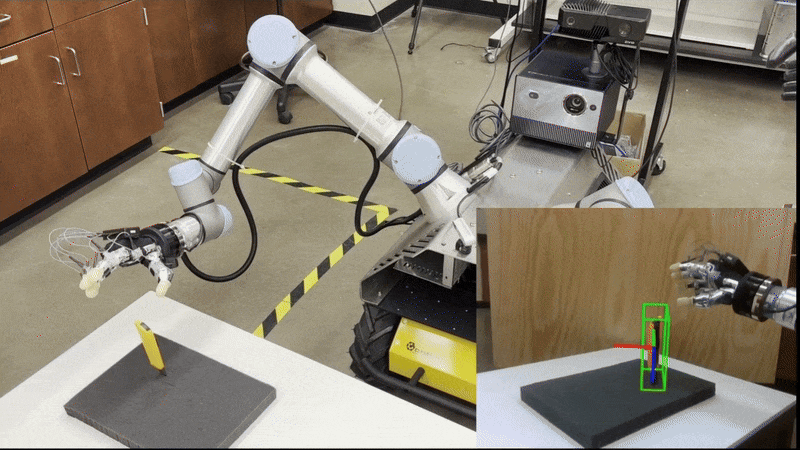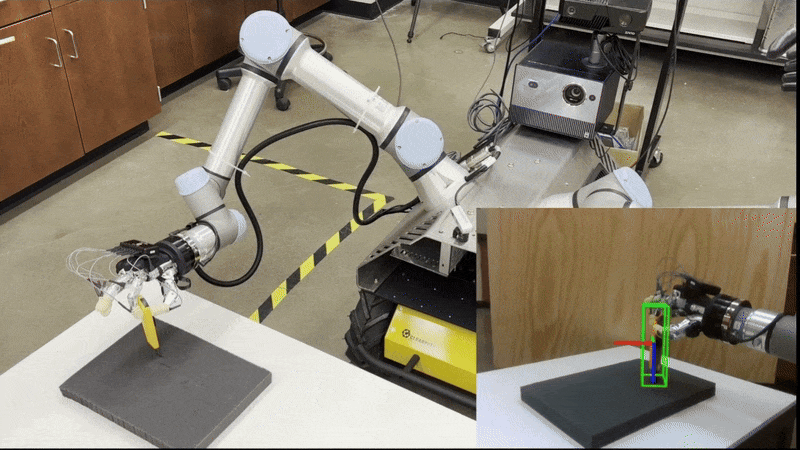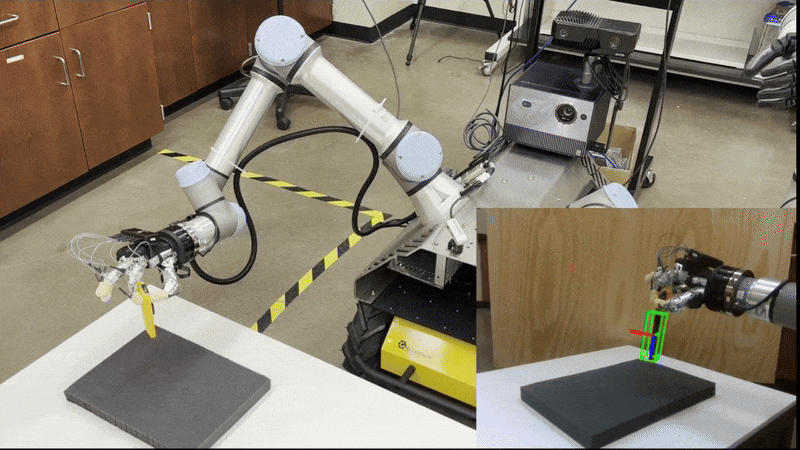 | Physically Structured Policy Learning for Contact-Rich Dexterous Manipulation Hui Li, Akhlak Uz Zaman, Fujian Yan and Hongsheng He IEEE Robotics and Automation Letters (RA-L) (Underview) |
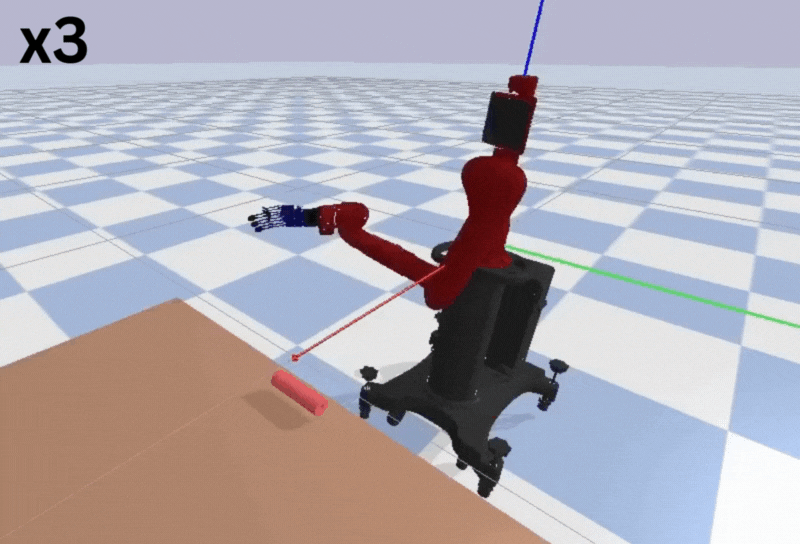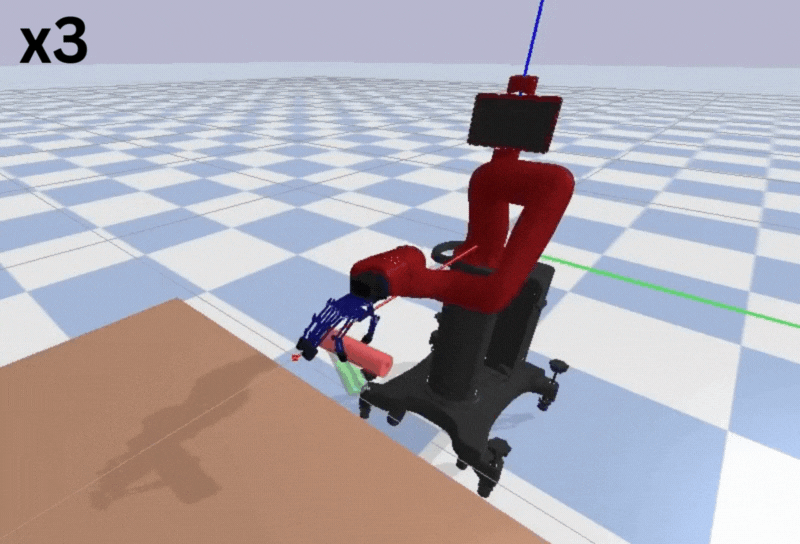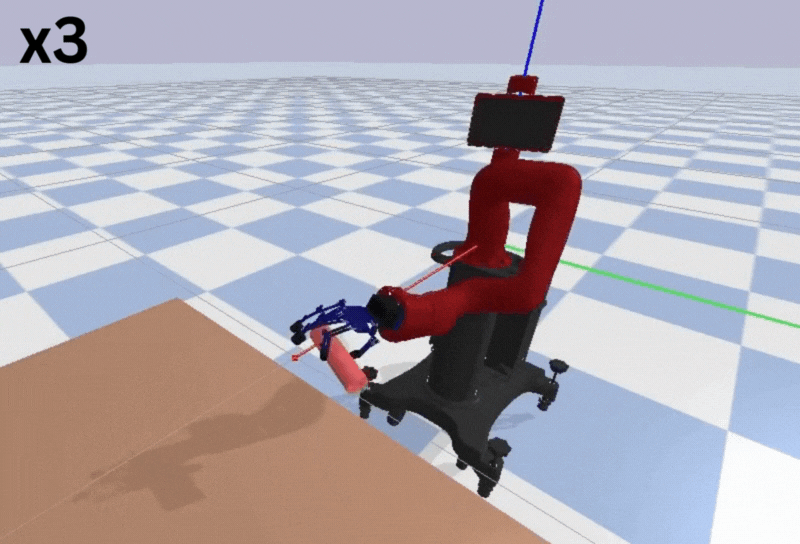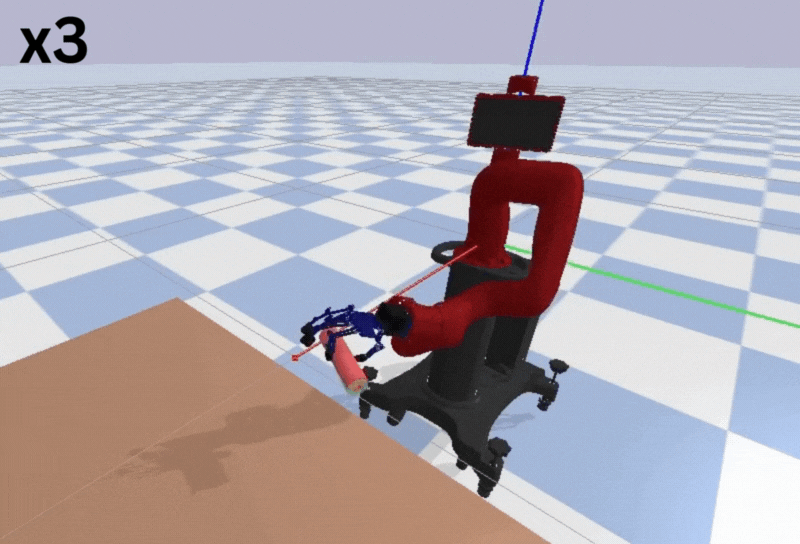 | Grasp Intention Interpretation in Object Handover for Human-Robot Teaming Hui Li, Akhlak Uz Zaman, and Hongsheng He International Conference on Social Robotics (ICSR 2024) Visit the [Paper] for more information. |
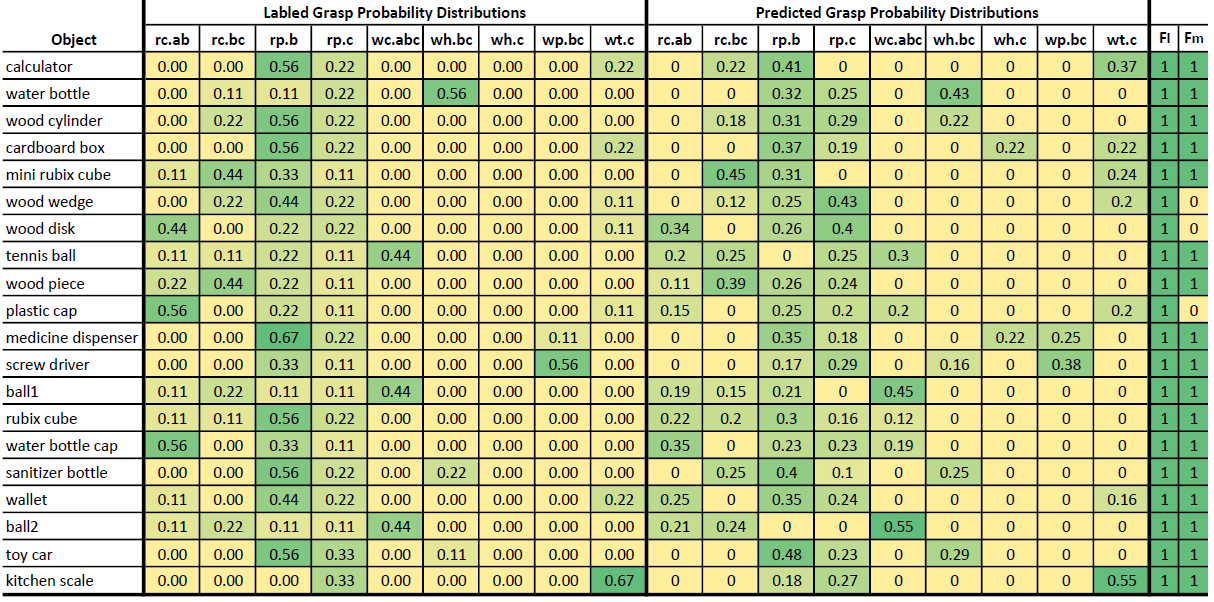 | Knowledge Augmentation and Task Planning in Large Language Models for Dexterous Grasping Hui Li, Dang Tran, Xinyu Zhang, and Hongsheng He IEEE-RAS International Conference on Humanoid Robots (Humanoids 2023) Visit the [Paper] for more information. |
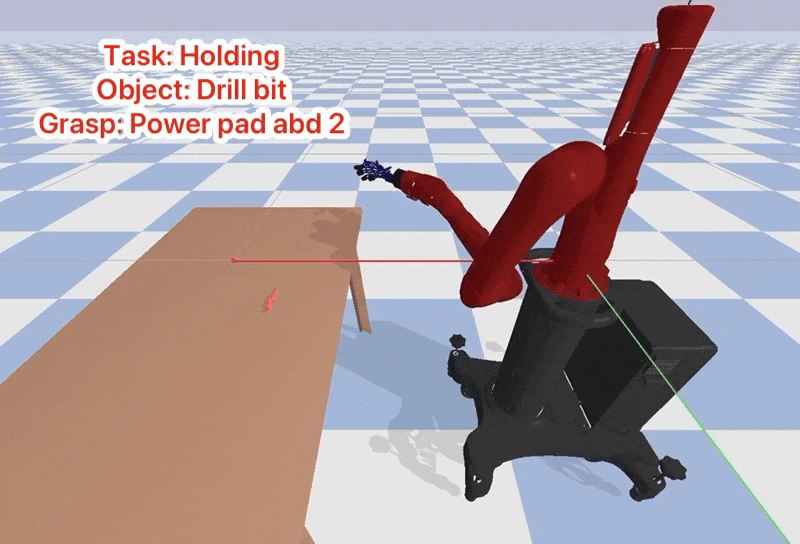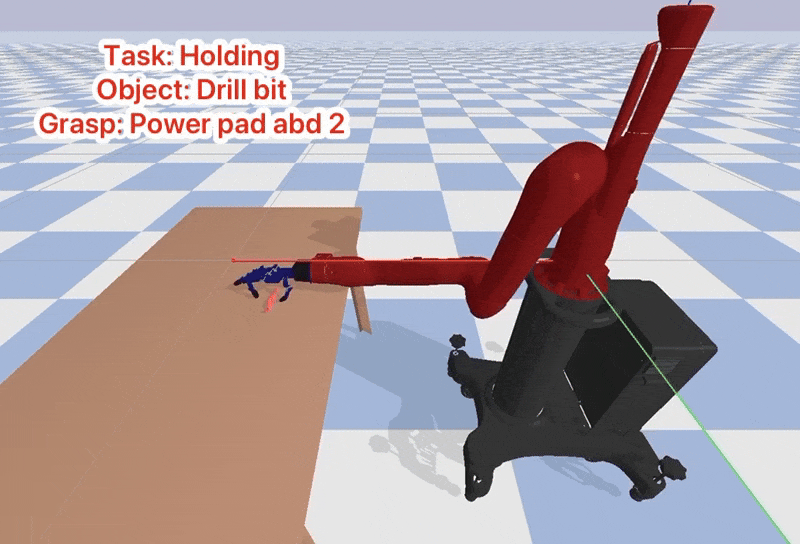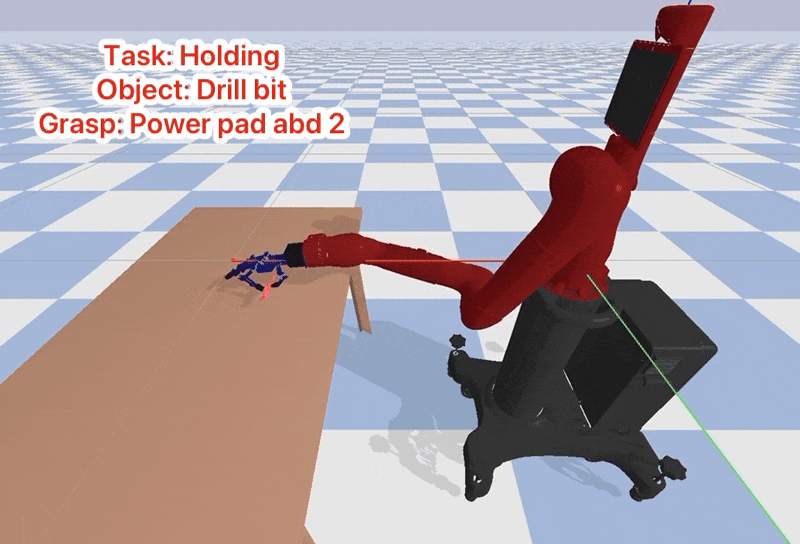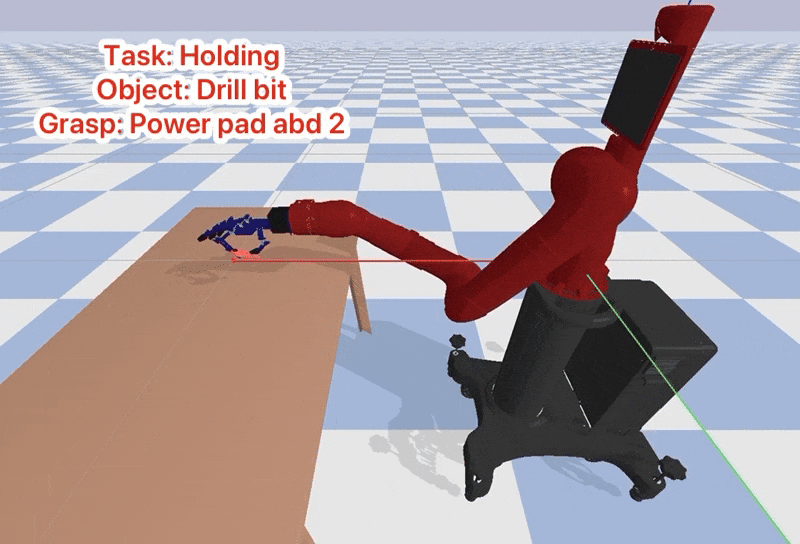 | Learning Task-Oriented Dexterous Grasping from Human Knowledge Hui Li, Yinlong Zhang, Yanan Li, and Hongsheng He IEEE International Conference on Robotics and Automation (ICRA 2021) Visit the [Paper] for more information. |
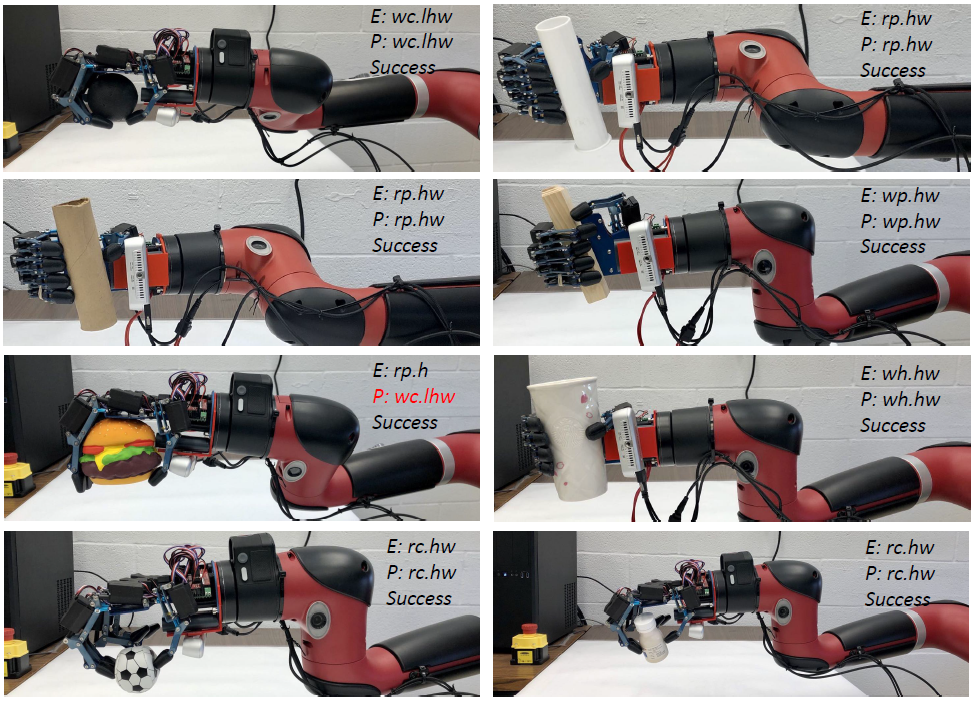 | MagicHand: Context-Aware Dexterous Grasping Using an Anthropomorphic Robotic Hand Hui Li, Jindong Tan and Hongsheng He IEEE International Conference on Robotics and Automation (ICRA 2020) Visit the [Paper] for more information. |